Question one: Rotor-loss recovery
01 / 05 Overview
Israel PenalosaAerospace and electrical engineering, KAIST
A rotor fails mid‑flight. What should the aircraft do next?
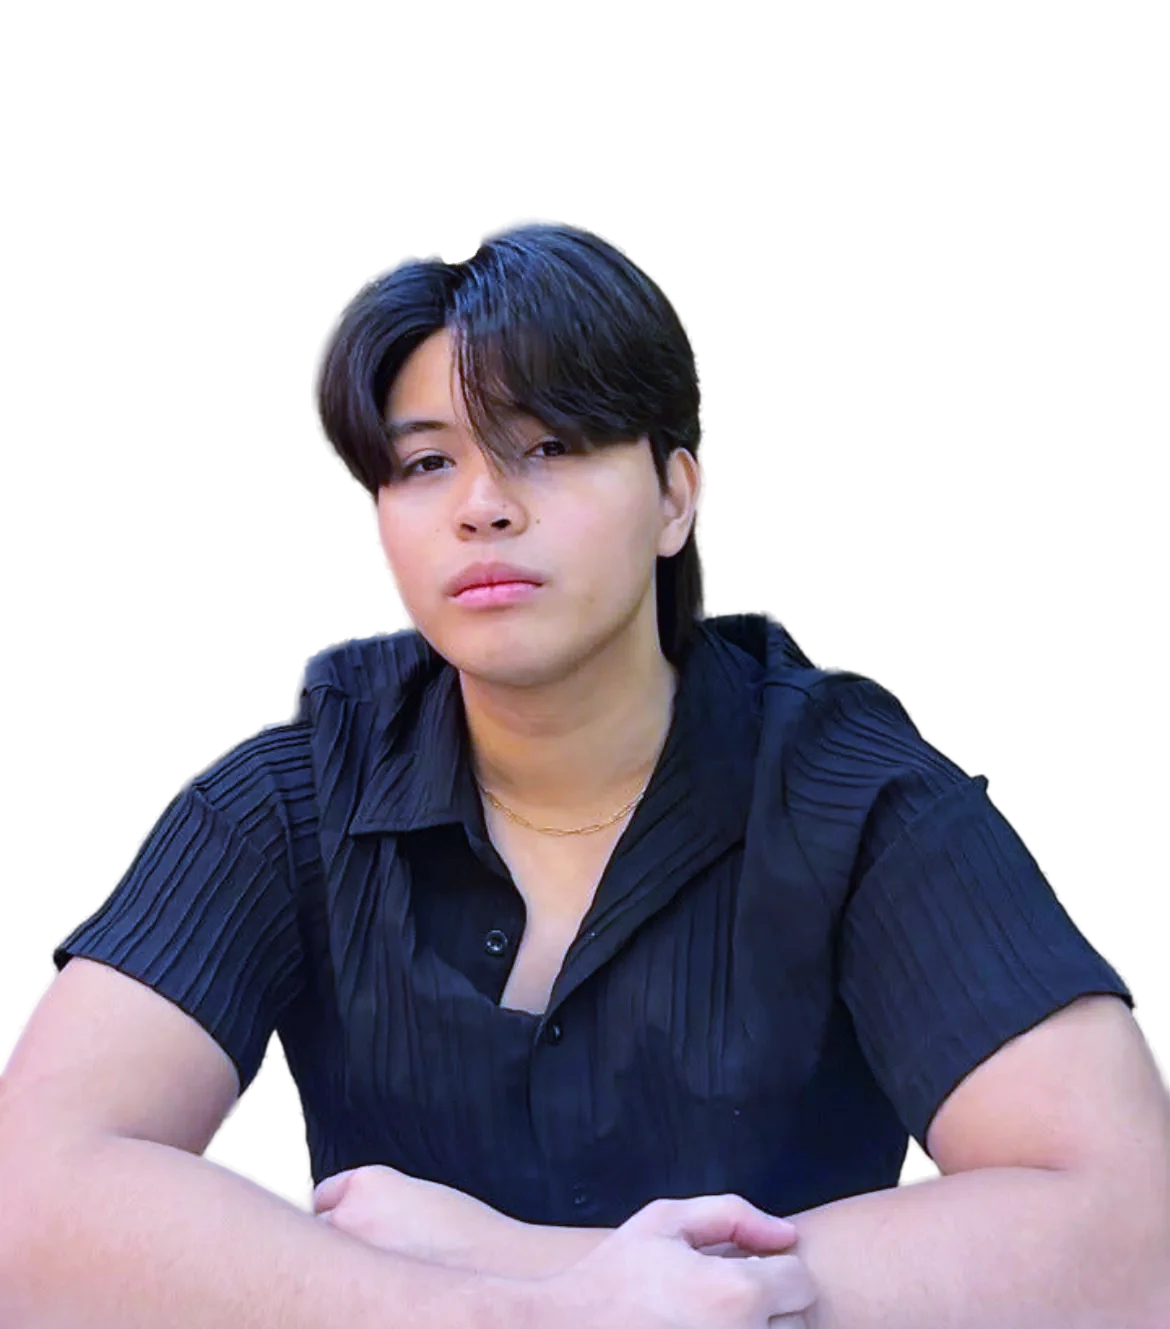
I'm Israel, an undergraduate at KAIST in aerospace engineering with a double major in electrical engineering. My research is about control for flight when things stop going to plan: a quadrotor that has just lost a rotor, and two civilian UAVs that have to work as a team.
02 / 05 Two questions
Two questions keep me busy.
One is about a single quadrotor in trouble. The other is about two civilian UAVs that have to work together. Each story says what is mine and what belongs to the team.
Question two: Cooperative guidance
Two civilian UAVs, one goal. When is predicting ahead worth it?
03 / 05 Research
What exists so far, and who made it.
A paper, an ongoing benchmark, the earlier control project and an individual study.
Losing one rotor changes what a quadrotor can do, and it happens fast. This study is about recovery at low altitude. It continues my earlier project on fault-tolerant drone control.
Paper statusAccepted for presentationat the 2026 Future Aerospace Conference
My part
First author with G. Kim on NMPC Teacher Distillation and Residual Reinforcement Learning for Low-Altitude Quadrotor Recovery after Rotor Loss.
I proposed the study, framed the control problem, and designed the experiments.
With the team
G. Kim, co-author, did the implementation and the simulation runs.
The controller and its results are the team's.
Penalosa and G. Kim. The paper behind question one.
Two civilian UAVs cooperate to reach one goal. This project compares a simple guidance method with a predictive one, to see when the simple one is enough.
StatusOngoingsince Jul 2026
My part
I built a Python simulation benchmark comparing simple and predictive guidance for two cooperating UAVs.
Done with
KAIST Undergraduate Research Participation
Advised by Prof. Han-Lim Choi.
Cooperative guidance for two civilian UAVs. The project behind question two.
The project that question one grew out of.
- When
- Jul 2025 to Jun 2026
- Mine
- I modeled quadrotor dynamics in Python, trained a controller and evaluated its behavior after simulated rotor loss.
- With
- Prof. Hyo-Sang Shin. Research intern, then competitively selected undergraduate researcher.
- Also
- Selected for the KAIST Undergraduate Research Participation workshop.
- Where
- KAIST Department of Aerospace Engineering
- When
- Jun 2024 to Jun 2025
- Mine
- I implemented feedback guidance in MATLAB and evaluated it in simulation.
04 / 05 Background
Background
Education
KAIST
Israel John Penalosa. Undergraduate, pursuing a B.S. in Aerospace Engineering with a double major in Electrical Engineering.
Aug 2022 to Feb 2028 (expected).
KAIST International Student Scholarship.
Research so far
- Oct 2026 to presentLow-altitude quadrotor recovery after rotor loss
- Jul 2026 to presentCooperative guidance for two civilian UAVs, advised by Prof. Han-Lim Choi
- Jul 2025 to Jun 2026Fault-tolerant drone control, with Prof. Hyo-Sang Shin
- Jun 2024 to Jun 2025Individual study, KAIST Department of Aerospace Engineering